Daisy Saurus
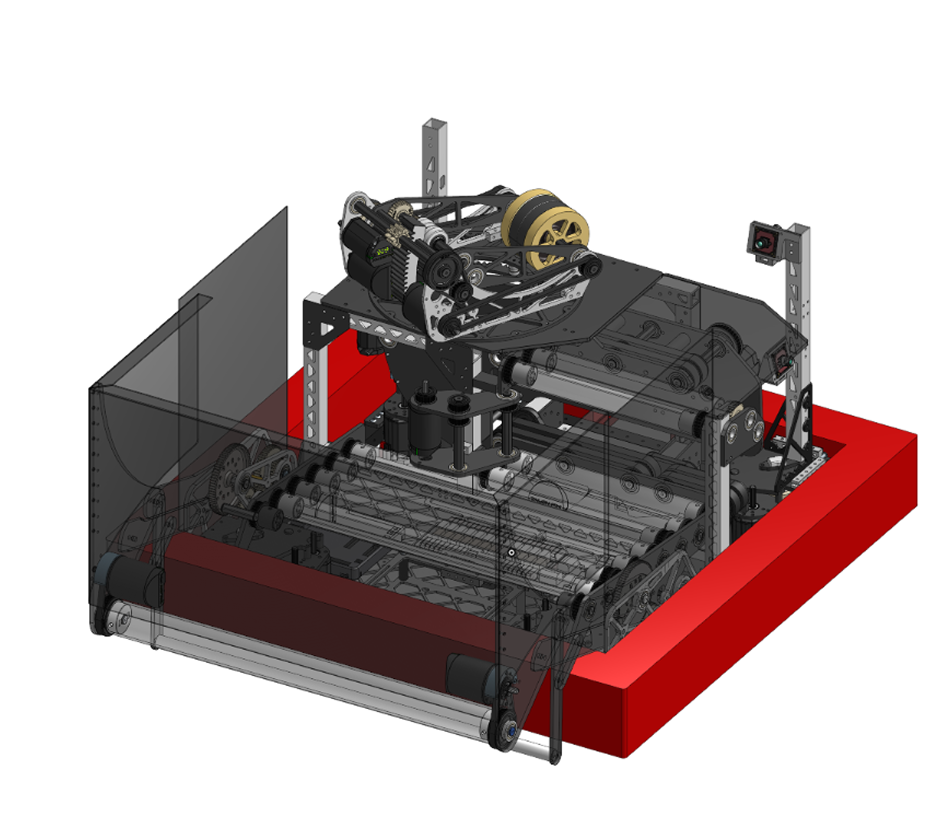
Features
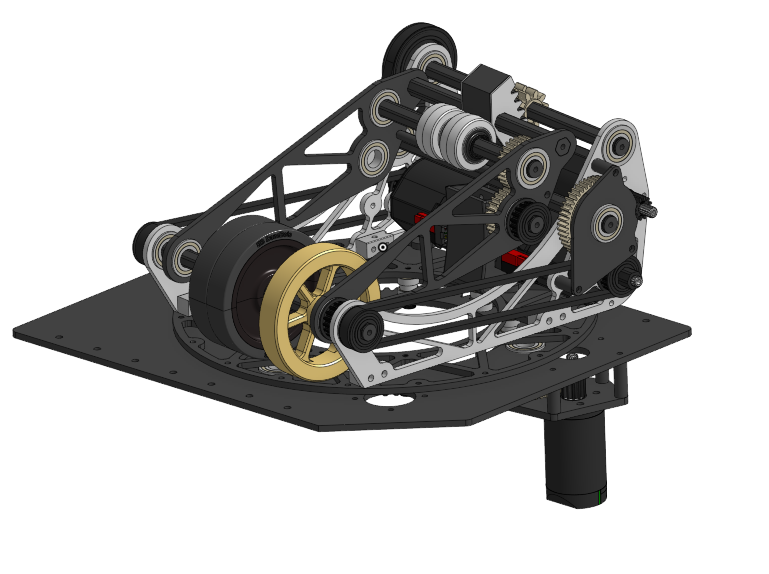
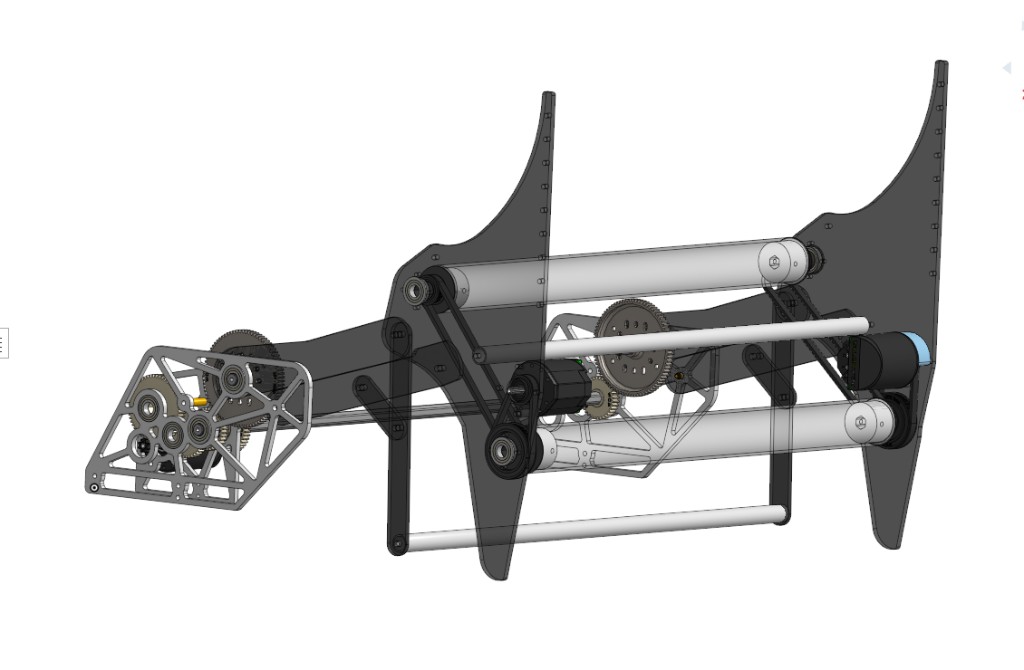
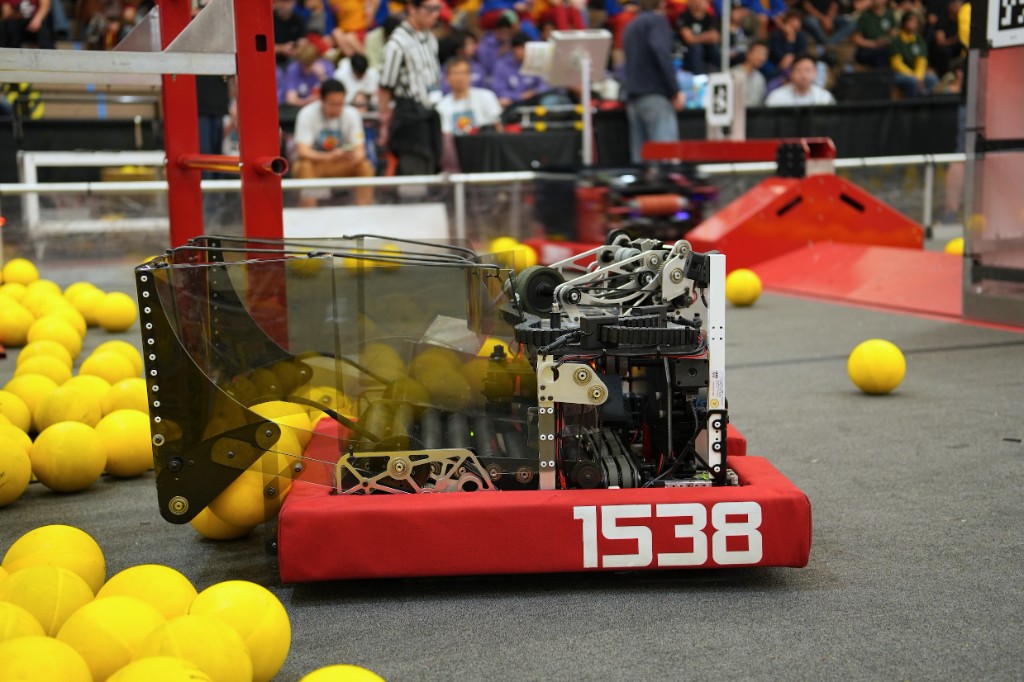
Shooter
- Turret-Style Shooter
- Rotates up to 360° independently of the drivetrain, allowing the robot to aim and shoot from any orientation.
- Variable-Angle Hood
- Adjusts the shot angle to support accurate scoring from multiple field distances.
- Vision Auto-Aiming
- Uses vision targeting to automatically detect goals and align the turret for accurate scoring.
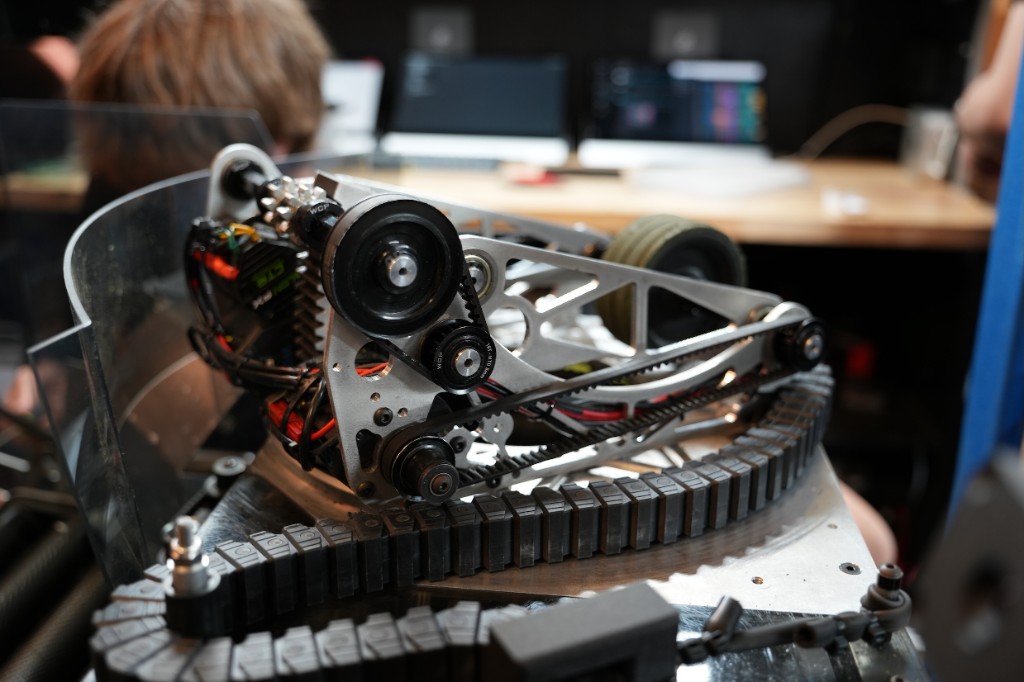
- Dual-Wheel Flywheel System
- Uses two 1.625-inch Colson wheels and two Banebots wheels powered by 2 Kraken X60 motors and 2 Kraken X44 motors, with 2 4-inch brass flywheels added to increase rotational inertia for more consistent shot velocity.
Intake
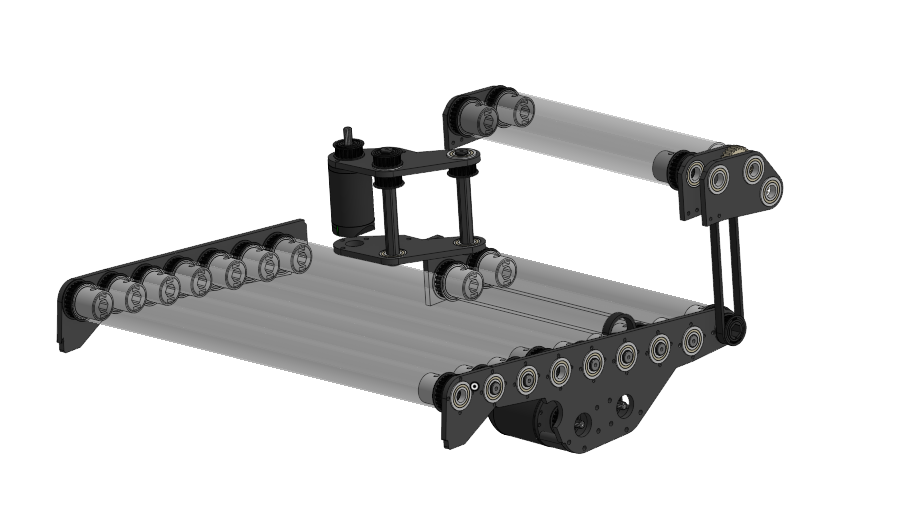
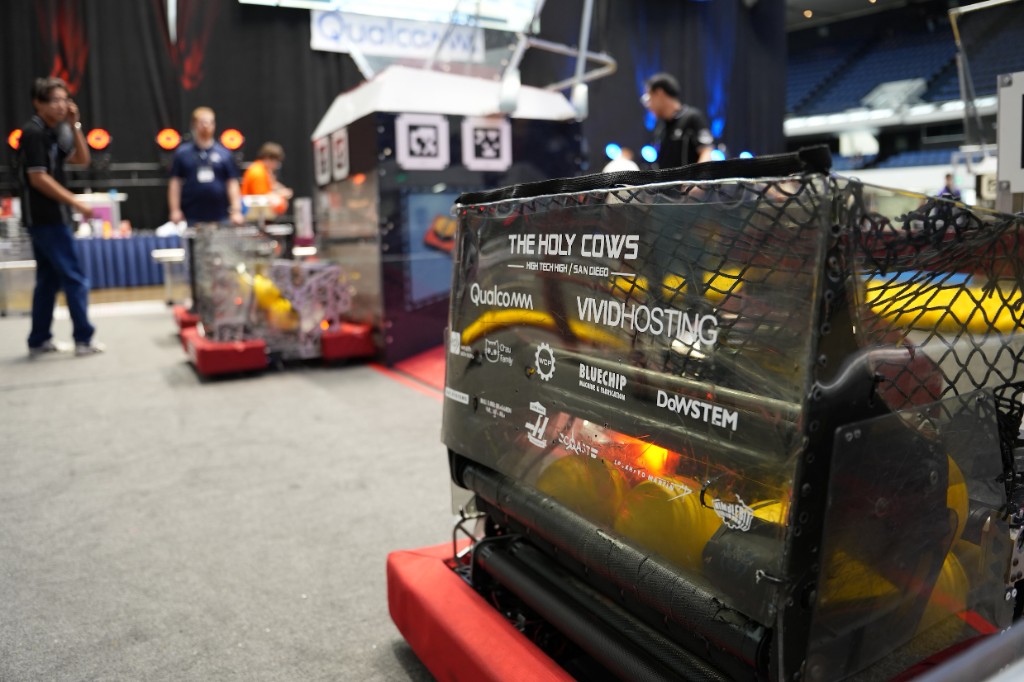
- Four-Bar Hopper Expansion
- Uses a four-bar linkage to expand the hopper and increase fuel storage capacity during operation.
- Intake
- Uses two Kraken X60 motors driving a 2-inch roller to capture and move fuel into the hopper.
- High-Speed Collection
- Collects up to 10 fuel per second to support rapid scoring cycles.
Feeder & Hopper Floor
- Kraken X60 Drive
- Uses Kraken X60 motors to power the feeder and hopper mechanisms for reliable fuel transfer.
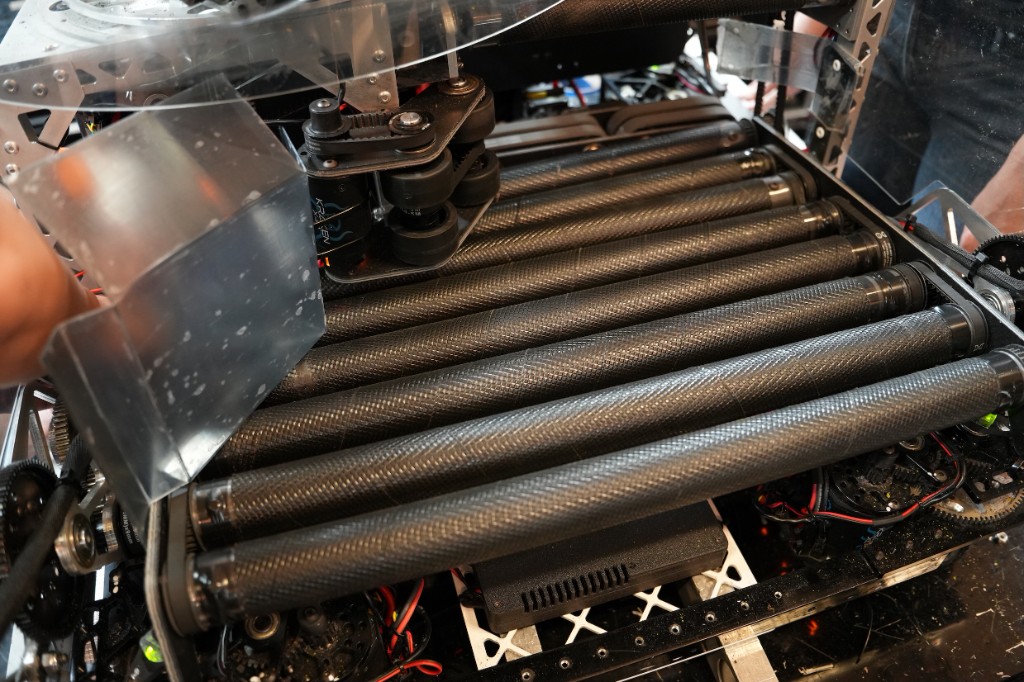
- High-Speed Roller System
- Uses seven 1.5-inch rollers with a surface speed of 43 ft/s to move fuel efficiently toward the feeder.
- Active Tunnel Feeder
- Uses a belt-driven tunnel system to serialize and shuttle fuel efficiently into the shooter for consistent feeding.
Drivetrain
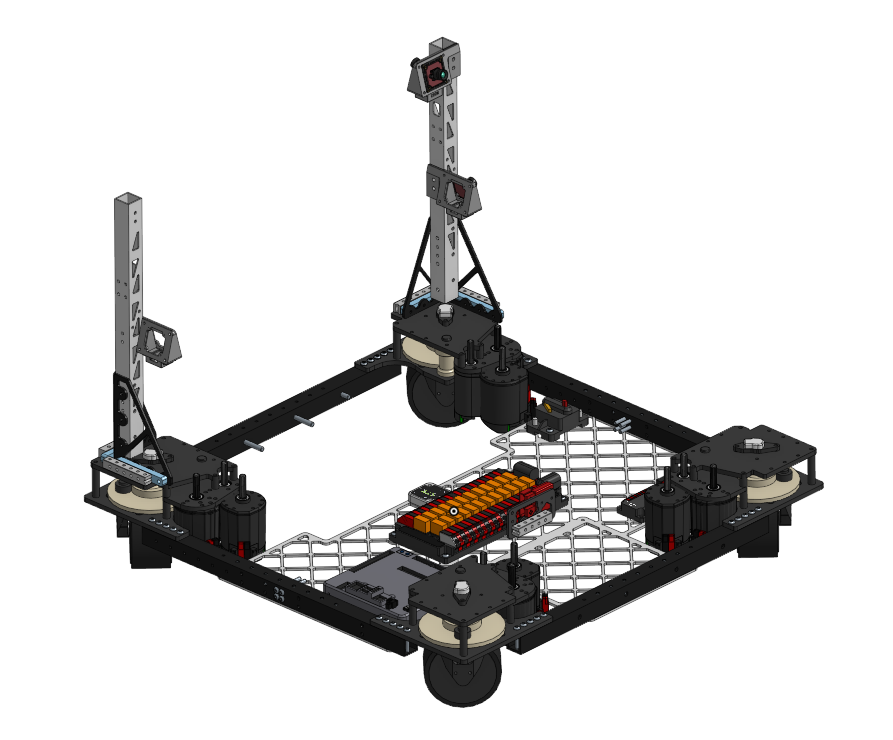
- Swerve Drive System
- Uses an omnidirectional swerve drivetrain to enable precise movement in any direction without rotating the robot.
- X2C Swerve Modules
- Operates on WestCoast Products X2C modules, designed for high performance, simplified assembly, and improved drivetrain versatility.
- High-Traction Wheels
- Uses wider swerve wheels to improve traction and acceleration during fast maneuvers.
- High-Speed Drive
- Reaches a top speed of 16.1 ft/s using a 6.48:1 gear ratio.
Software
- C++ Control Software
- Uses C++ as the primary programming language for robot control and subsystem coordination.
- Multi-Camera Vision System
- Uses multiple cameras and custom computer vision software running on an onboard LattePanda single-board computer for real-time vision processing and field pose estimation.
- Adaptive Shot Control
- Uses vision-based pose estimation and a physics-based model to automatically adjust shooter velocity and hood angle while compensating for robot motion.
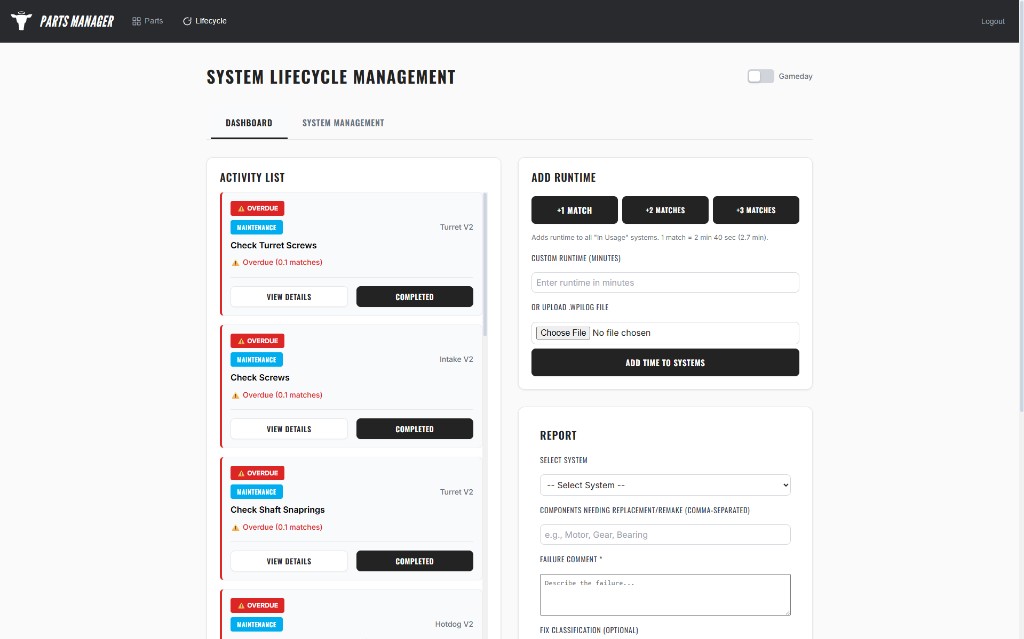
Lifecycle Management
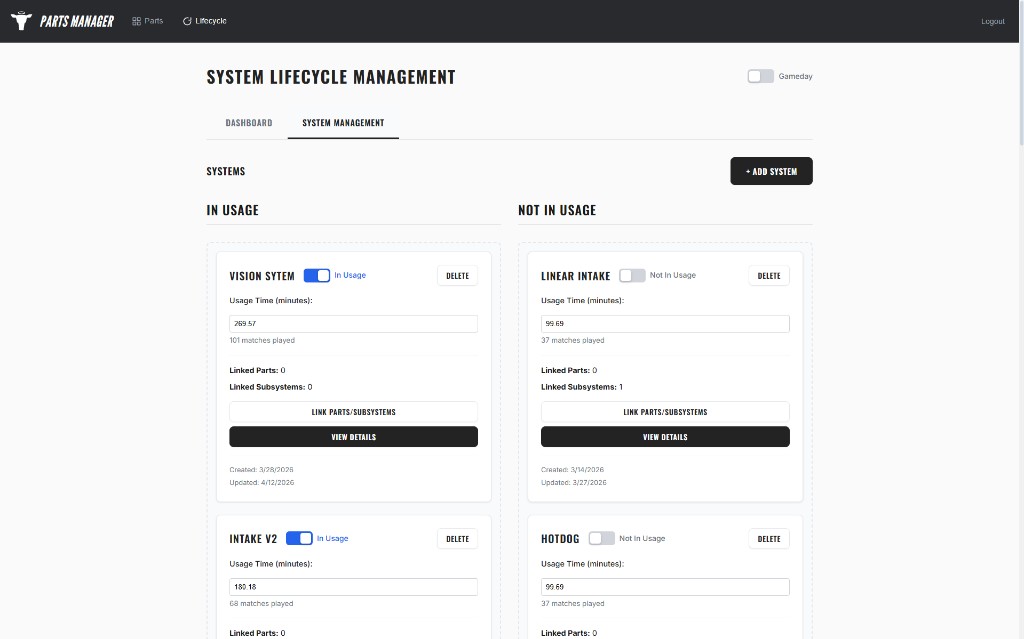
- Failure Tracking System
- Tracks component failures to calculate mean time between failures (MTBF) and improve system reliability.
- Predictive Maintenance
- Uses failure data to generate maintenance schedules for critical robot systems.
- Cycle & Runtime Monitoring
- Tracks maximum part and assembly cycles along with subsystem runtime to guide preventative maintenance and replacements.
Gallery
2026 Season at a Glance
Official match and district performance through the 2026 FIRST California district season.
- Wins
- 35
- Losses
- 15
- Ties
- 0
- Win Rate
- 70%
- CA District Rank
- #10
- District Points
- 261
Source: The Blue Alliance
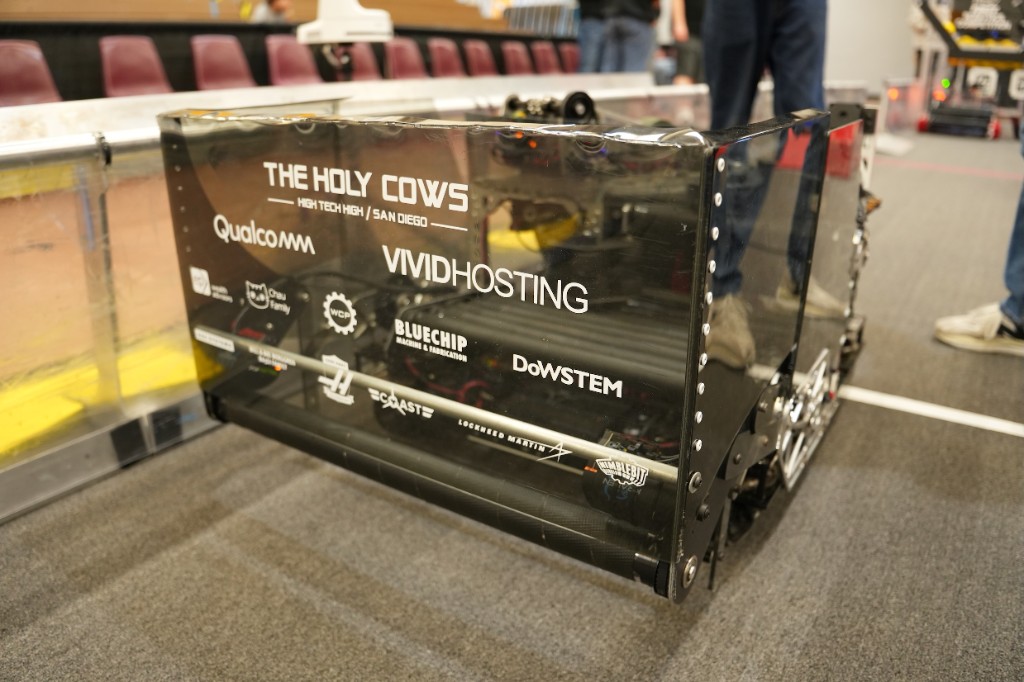
Powered By Our Sponsors